Field deployment & fleet operations
Taking autonomous robots from the crate to a live shift, and keeping them there.
- Site integration and go-live
- Preventative maintenance programs
- SOPs and operator hand-off
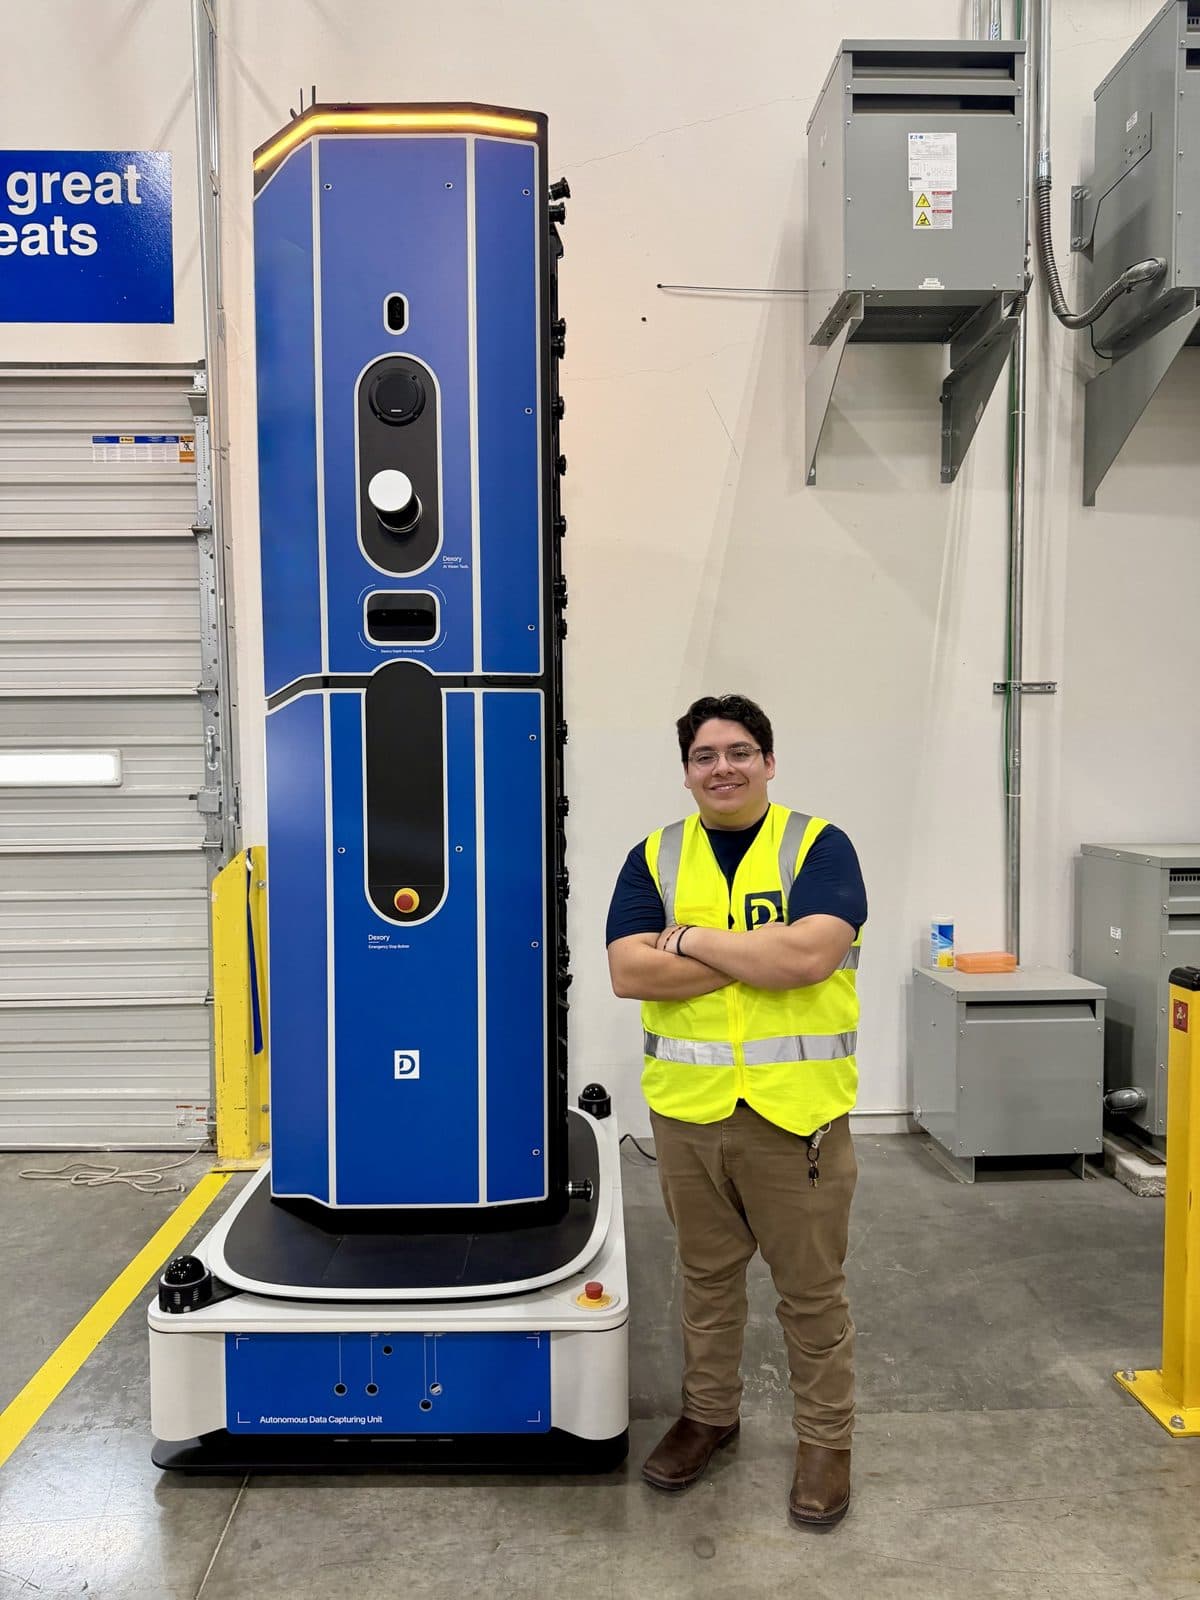
NowDeployment Engineer at Dexory
I'm Chris Garza, a robotics and embedded systems engineer who takes hardware from schematic to the field. I deploy autonomous inventory robots across three countries at Dexory, previously kept a humanoid fleet at 98% uptime, and I'm co-founding Icarus to make 3D print farms run themselves.
Dallas–Fort Worth, TX
Experience with
Tap a station in the scene to read about it.
What I do
Three kinds of work I take on, for robotics teams that need hardware to perform outside the lab.
Taking autonomous robots from the crate to a live shift, and keeping them there.
Power, wiring and firmware that survive vibration, impacts and long shifts.
Production cells that run without babysitting, from CAD to the software that schedules them.
Experience
Deployment engineering taught me what breaks in the real world. Icarus is where I design so it doesn't.
Deployment Engineer
US · Mexico · Canada
Dexory builds autonomous robots that scan warehouse racking up to 18 m high with an extendable vision tower, turning every aisle into a live digital twin of inventory.
Co-Founder & Lead Engineer
Dallas, TX
Automated 3D print farm built around zero-touch production: robotic part extraction, fleet-scale scheduling and an in-house operations platform.
Junior Field Deployment Engineer
Customer sites · US
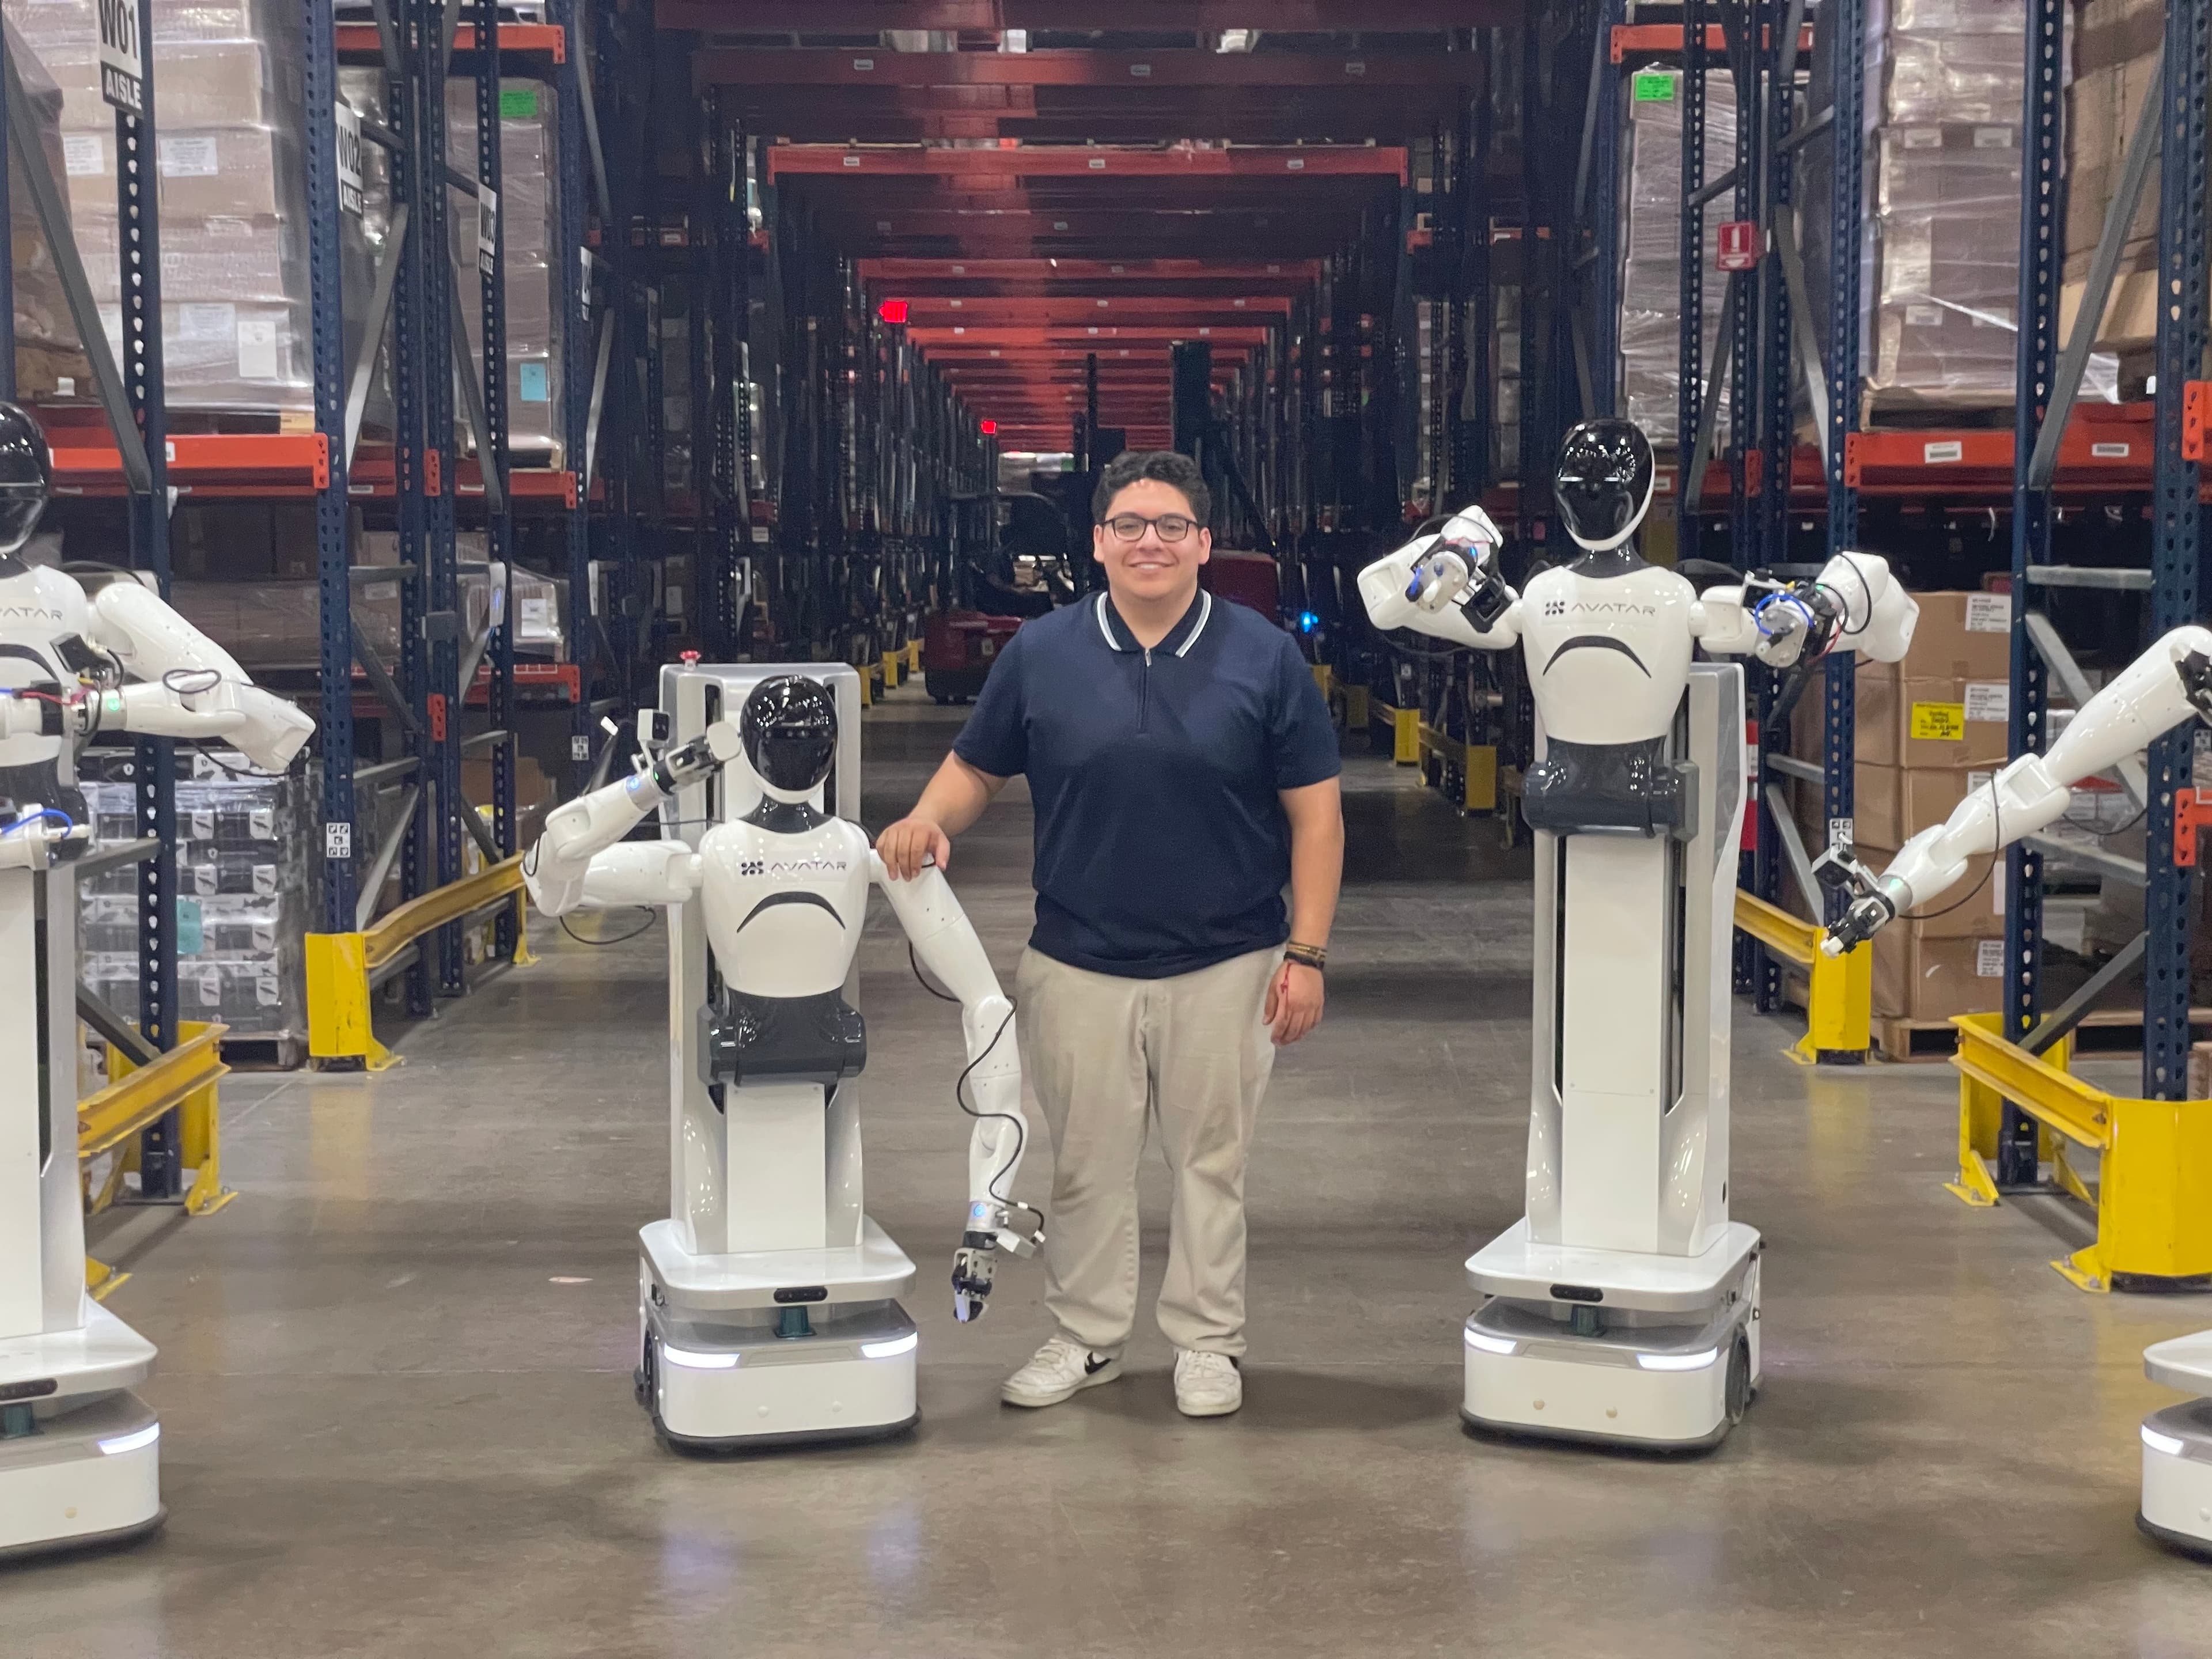
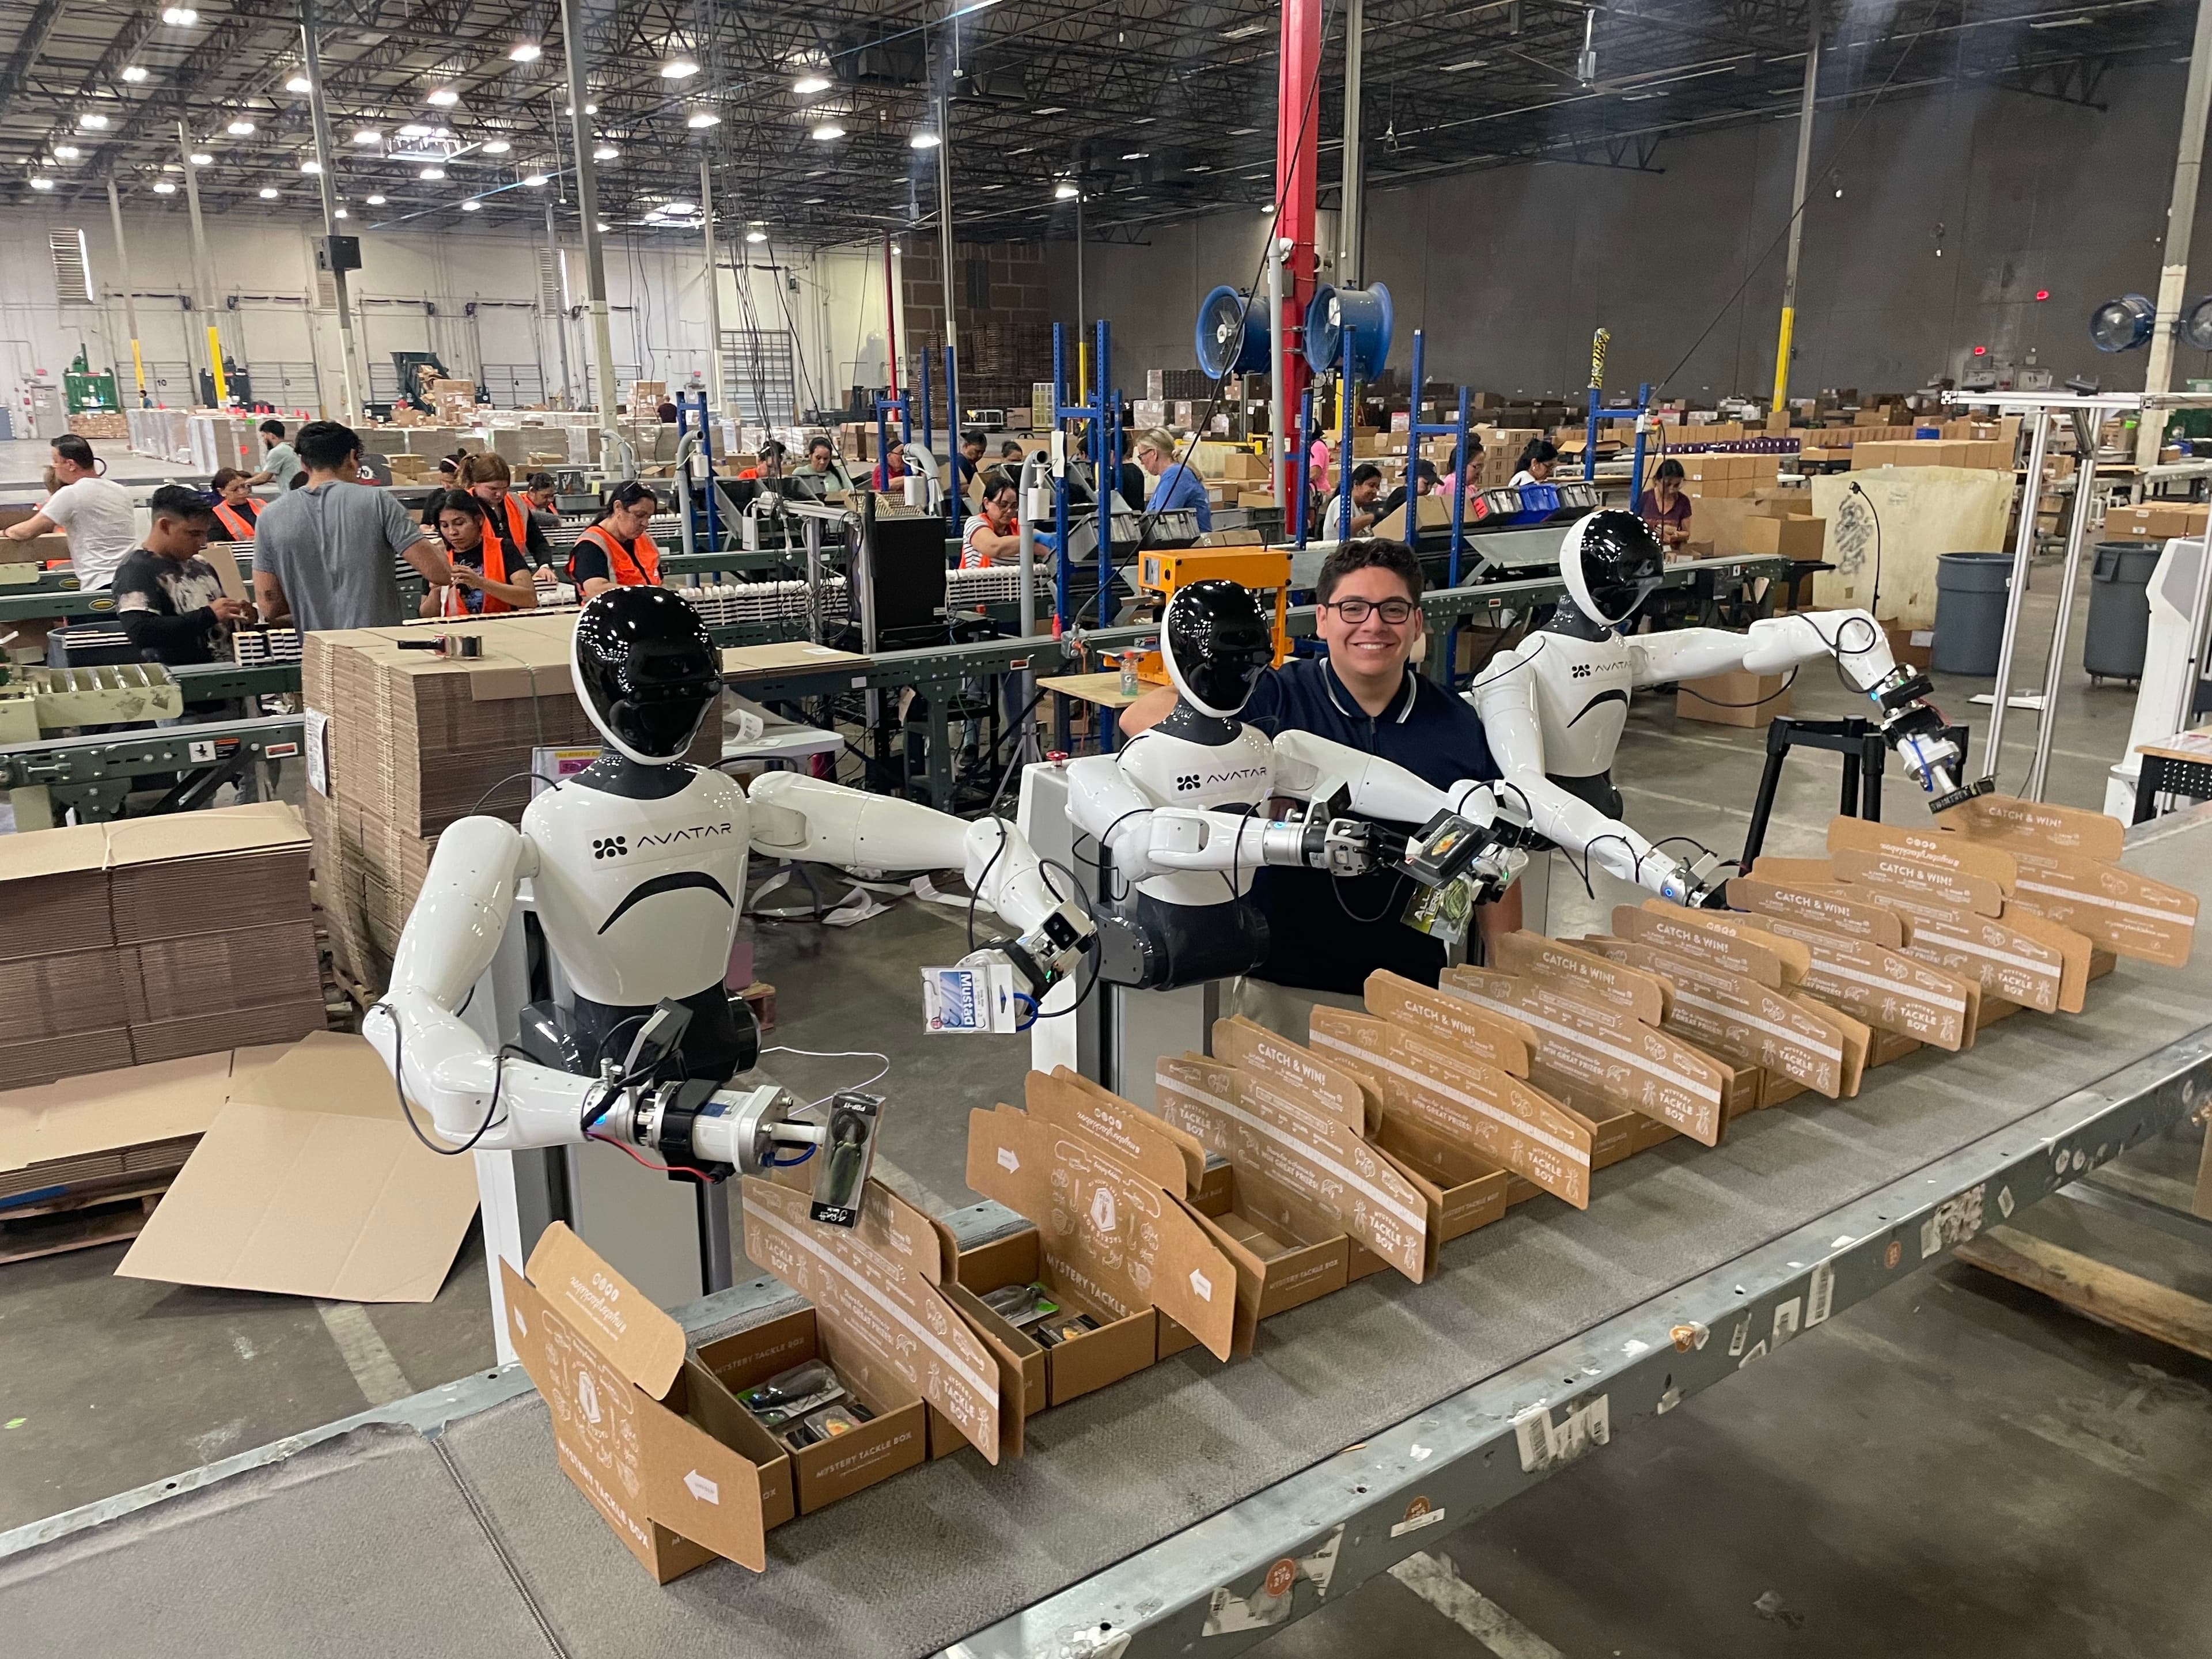
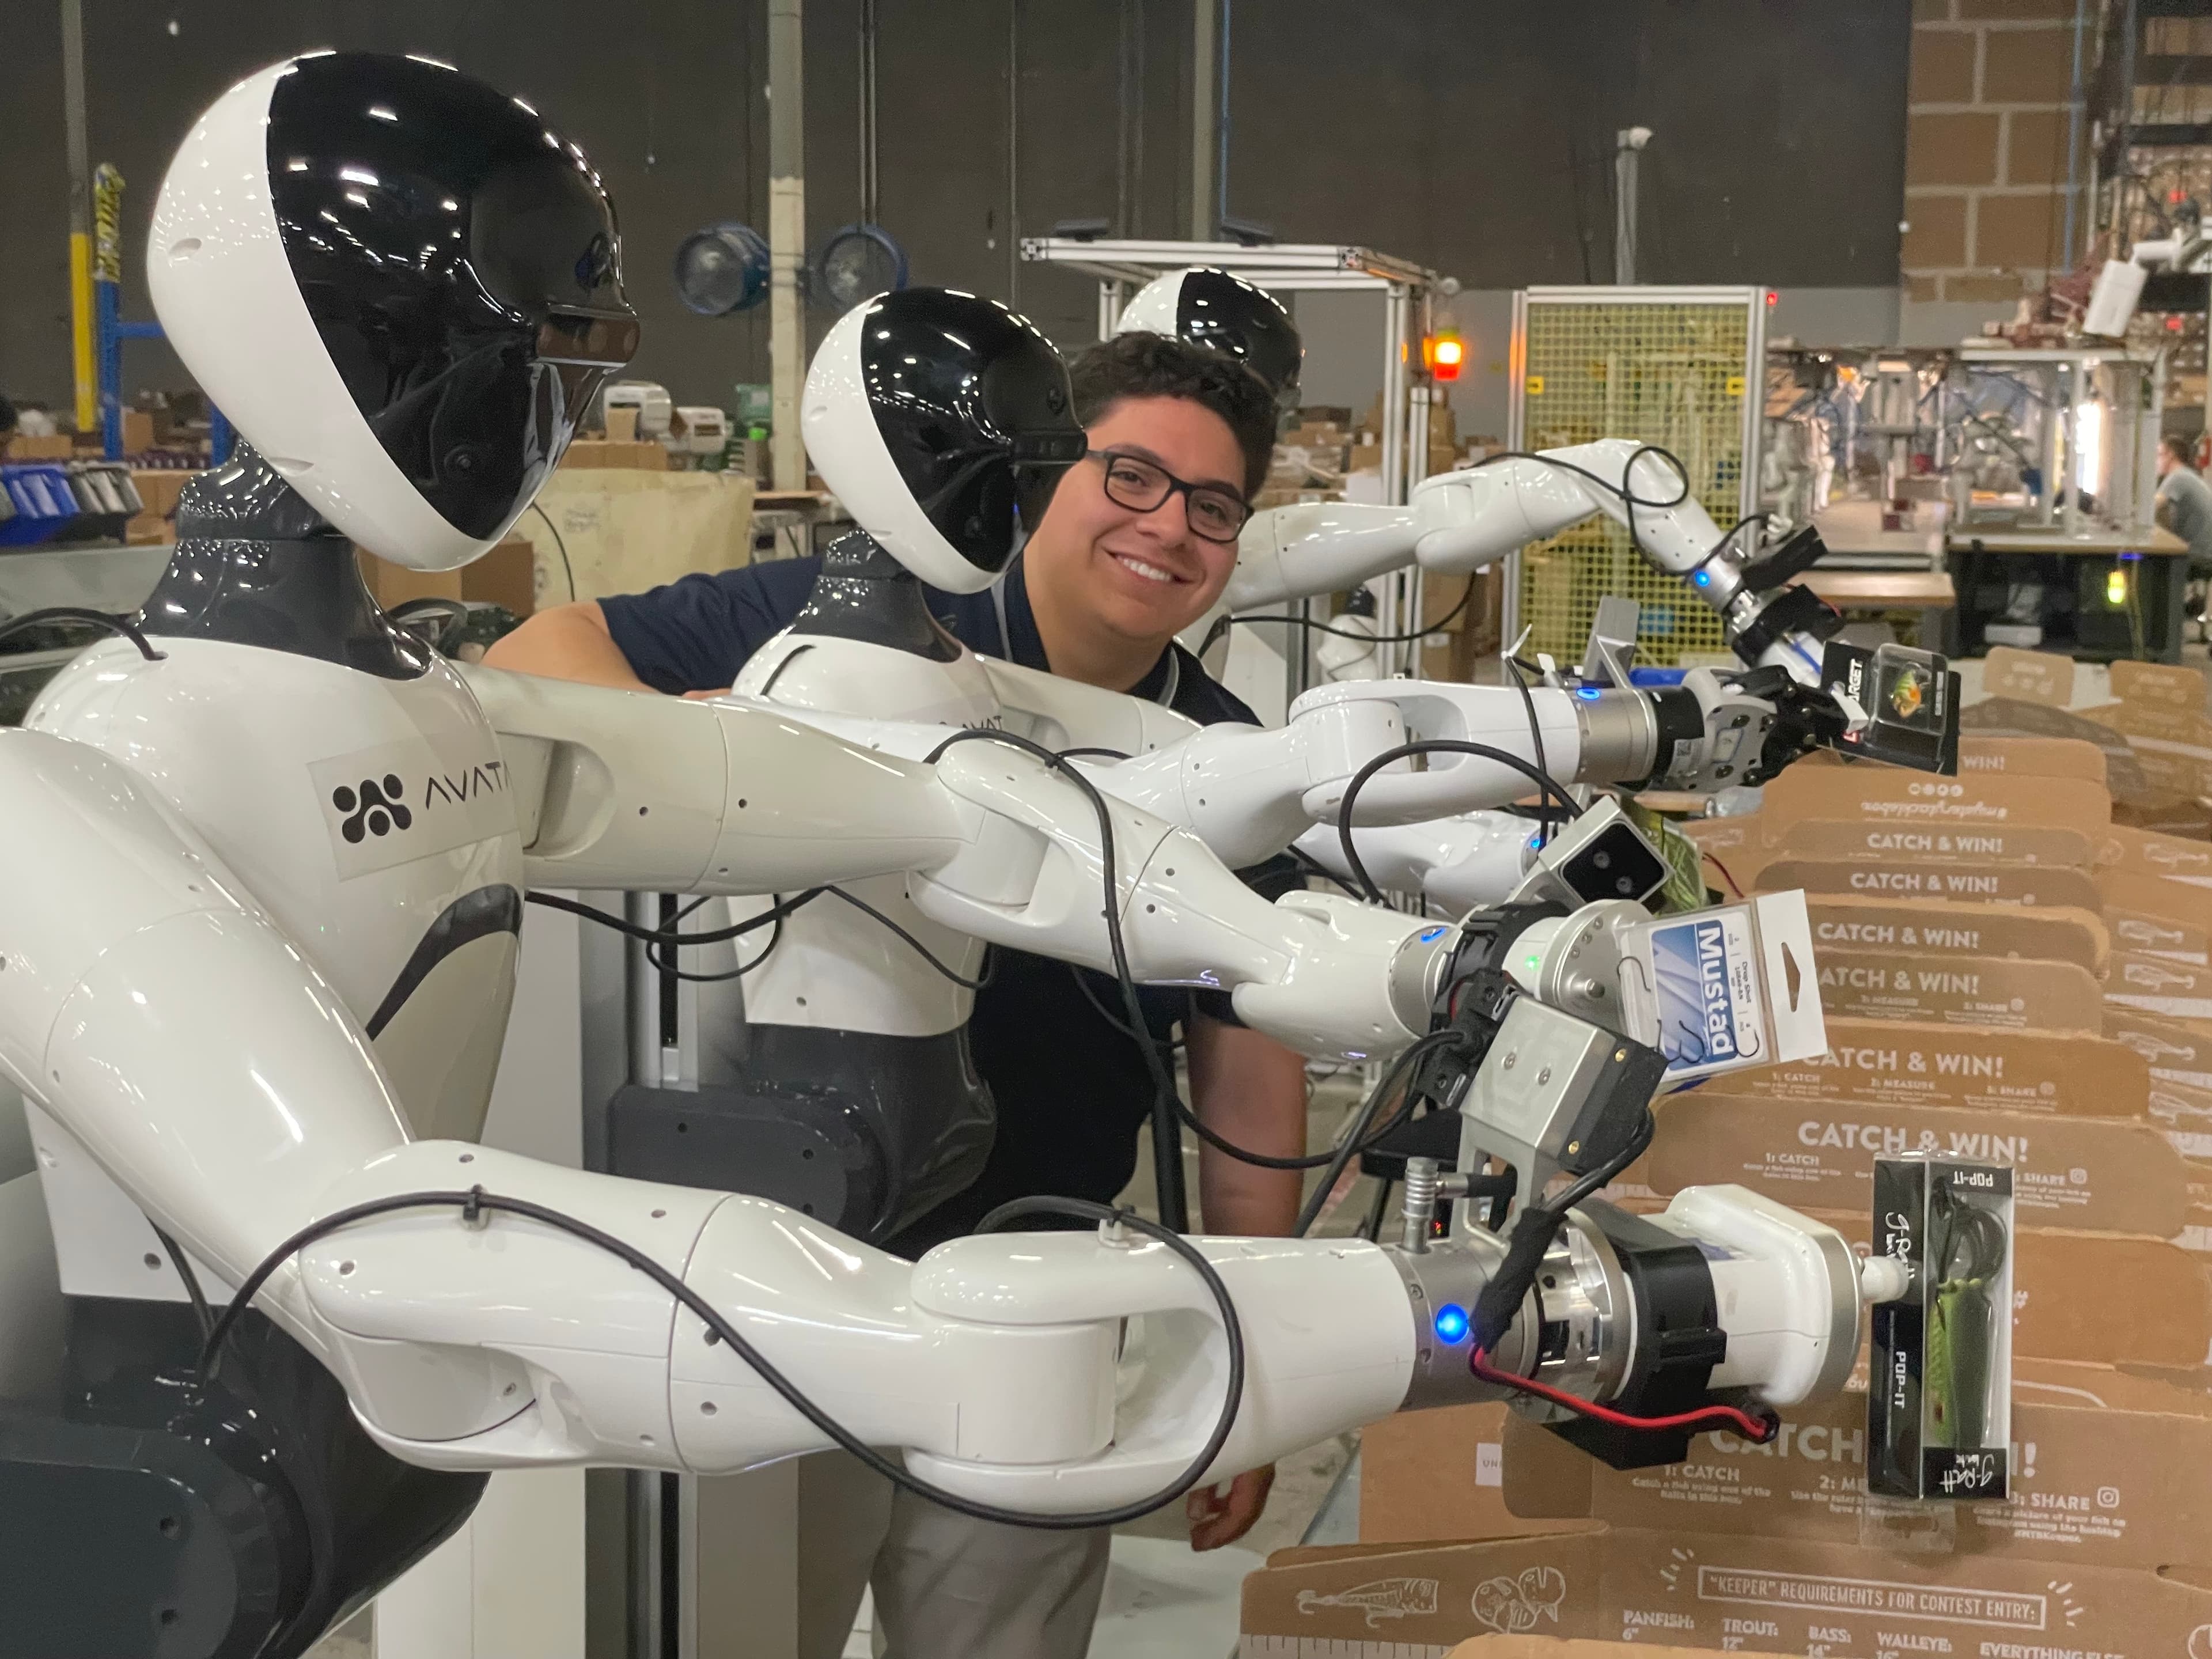
Kept a fleet of humanoid and mobile robots running in live warehouse and fulfillment environments. Promoted from Field Deployment Representative to Specialist to Junior Field Deployment Engineer, leading integration and field deployments.
Vice President & Electrical Lead
Arlington, TX
Led electrical architecture for a competitive combat-robotics team that placed 2nd in Texas and 10th nationally at RMNA 2025.
Undergraduate Research Assistant
Arlington, TX
Industrial engineering and advanced robotics research with Dr. Overton.
Selected work
Competition robots, production automation and the software that runs it.
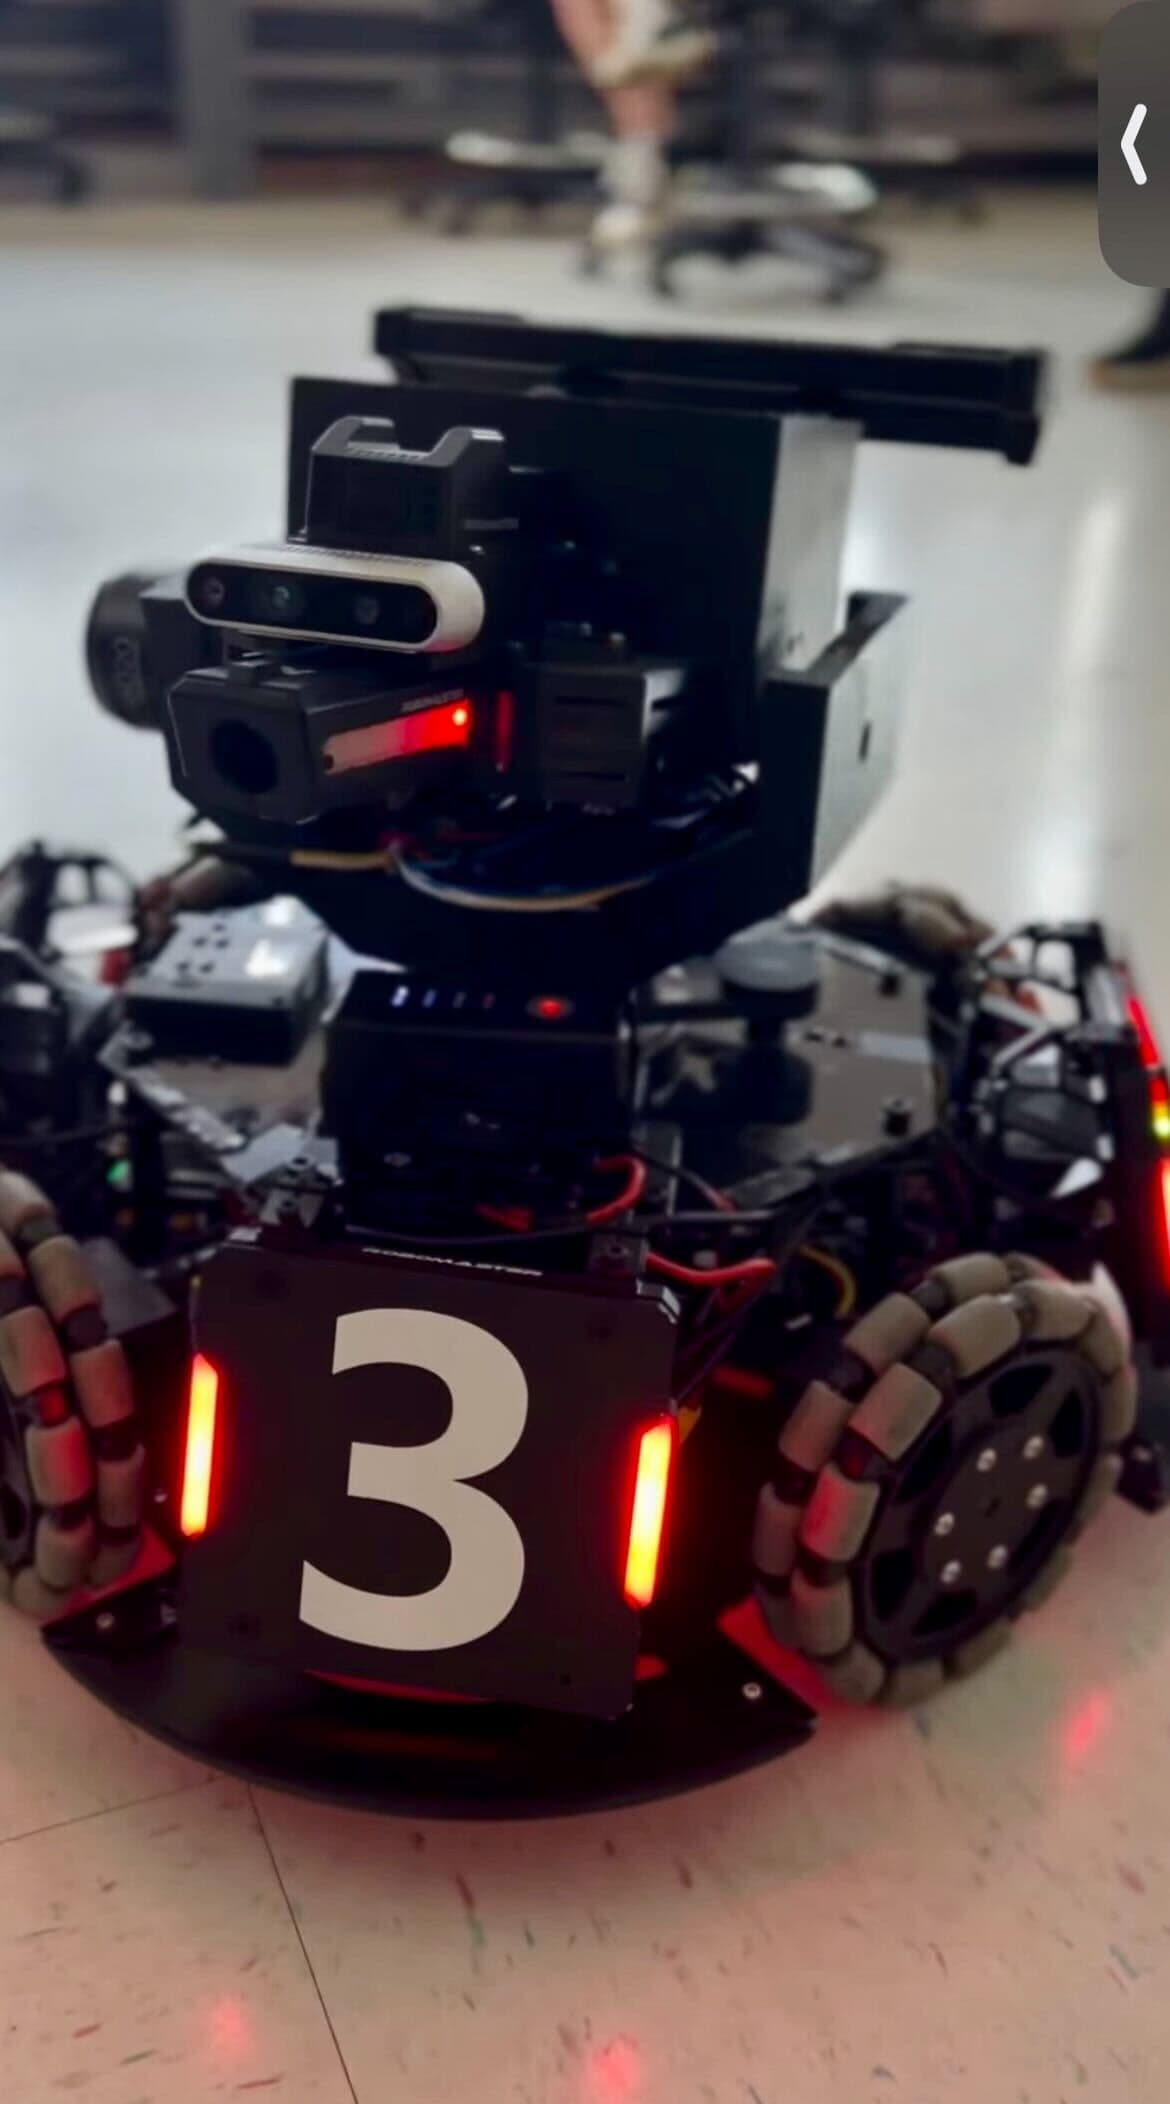
VP & Electrical Lead · UTA Robomasters
Combat robot with a custom X-drive suspension for omnidirectional movement at full speed. Owned the electrical system end to end: harnesses, power distribution, sensors and control firmware.
2nd in Texas · 10th nationally (28 teams)
AI fitness & nutrition tracking
AI-assisted fitness and nutrition tracker that turns logged meals and workouts into adaptive targets. Cross-platform client with a Supabase backend and a web dashboard.
Zero-touch print farm
Robotic part removal that clears finished prints from the build plate and queues the next job, turning a print farm into a lights-out production cell.
Inventory & job tracking for Icarus
Real-time filament inventory, job tracking and printer fleet status. Stock alerts and automated reorder triggers keep production from stalling on materials.
2016 Chevrolet Malibu
Parametric widebody panels modeled to the car's exact geometry, split for print-bed fit and printed in TPU and ABS for flex and UV resistance.
National Association of Rocketry member
Rocket designs simulated in OpenRocket for stability margin, apogee and recovery before anything gets built.
Capabilities
Hardware first, then manufacturing, then the software that ties it together.
Education
Robotics & Embedded Systems Engineering
University of Advancing Technology (UAT)
About
I like the part of robotics most people never see: the moment a machine leaves the lab and has to work on a real floor, for a real shift, next to real people. At Avatar Robotics that meant keeping a humanoid fleet at 98% uptime, one connector, one firmware patch and one SOP at a time.
Today I'm a deployment engineer at Dexory, putting autonomous inventory-scanning robots to work in live warehouses. Alongside that I'm studying Robotics and Embedded Systems Engineering at UAT and building Icarus, an automated print farm where robots pull finished parts and restart jobs without anyone touching the machines. It's the same problem from the other side: designing hardware that scales because it doesn't need babysitting.
I work across the stack, from KiCad schematics and STM32 firmware to SolidWorks assemblies and the Flutter or Next.js apps that run the operation. Bilingual in English and Spanish.
Contact
Hiring for robotics, deployment or embedded roles, or curious about Icarus? Reach out directly or send a note here.